Butter Above Raisin
Agent runs
Each mode of this task runs once per run. Est. cost is tokens at list price (data/prices.yml), never a bill; see the RoboLab runs for every task of a run.
Codex + GPT-6 Luna, reasoning xhigh (ChatGPT login)default run
| Trial | Started | Agent time | Model requests | Tokens in / out | Est. cost | Grade |
|---|---|---|---|---|---|---|
| U✓ 16m | 09-27 20:03 | 16m | 41 | 1.8M / 16k | $0.033 | deterministic 1, grader_error 0, instance_exact 1, instance_ok 1, n_actions 159, video_rendered 1 |
| L✗ 35m | 09-29 06:45 | 35m | 110 | 10.3M / 71k | $0.160 | deterministic 1, grader_error 0, live_success 0, n_actions 404, replay_success 0, video_rendered 1 |
Task instruction (upstream)
Pick up the butter box and place it on top of the raisin box
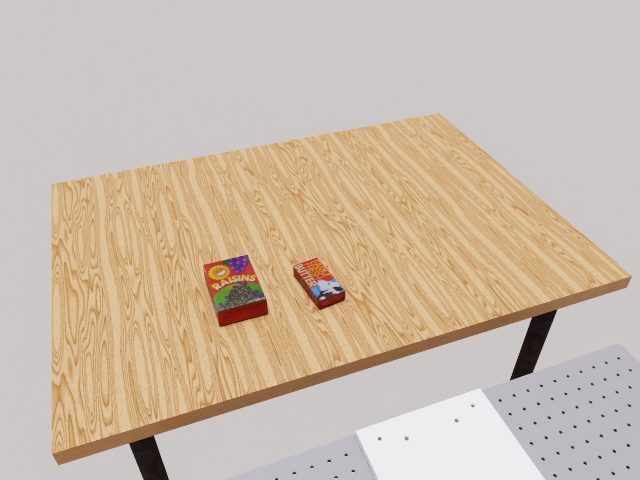
No oracle video published upstream — this is the scene it starts from.
What RoboLab states about this task
| Success predicate | object_on_top |
| Predicate arguments | object: butter · reference_object: raisin_box · require_gripper_detached: True |
| Scored subtasks | 1 |
| Subtask predicates | pick_and_place |
| Objects | butter raisin_box |
| Upstream attributes | spatial |
| Upstream difficulty | simple |
| Episode budget | 40 s |
| Other wordings | specific — Place the butter on top of the raisin box. The butter should end up on the raisin box. vague — Put butter on raisin box |
| Environment class | ButterAboveRaisinTask |
| Upstream name | ButterAboveRaisinTask |
| Defined in | robolab/tasks/benchmark/butter_above_raisin_task.py |
From https://github.com/NVlabs/RoboLab @ v0.3.1.
Tags
Task DomainManipulation
Skill primitives in the demo: spatial
Why this task is interesting
Not yet written.
Capability notes
Not yet written.
Oracle demo review
Not yet reviewed.