Kinematic3D · Packing 3D
Excluded from the benchmark
not among the hardest (robot_coding_bench 2026-10-04): GPT-6 Luna passed it in both modes
Greyed and last in the task list, left out of the benchmark's numbers; its demo and agent runs stay (excluded: in state/tasks/kinder.yml).
Agent runs
Each mode of this task runs once per run. Est. cost is tokens at list price (data/prices.yml), never a bill; see the KinDER runs for every task of a run.
Codex CLI 0.157–0.159 + GPT-6 Luna, reasoning medium (OpenRouter)default run
| Trial | Started | Agent time | Model requests | Tokens in / out | Est. cost | Grade |
|---|---|---|---|---|---|---|
| U✓ 9m | 09-29 15:31 | 9m | — | 2.6M / 33k | $0.050 | deterministic 1, grader_error 0, missing_trajectory 0, n_actions 196, video_rendered 1 |
| L✗ 1h 00m | 10-01 14:17 | 1h 00m | — | 21.5M / 195k | $0.362 | deterministic 1, grader_error 0, live_success 0, missing_log 0, n_actions 331, replay_success 0, video_rendered 1 |
1 other run(s) of KinDER
Codex CLI 0.159.2 + GPT-6.1 Sol, reasoning medium (OpenRouter)
| Trial | Started | Agent time | Model requests | Tokens in / out | Est. cost | Billed | Grade |
|---|---|---|---|---|---|---|---|
| U✓ 4m | 10-01 05:55 | 4m | 18 | 718k / 7k | $0.243 | $0.270 | deterministic 1, grader_error 0, missing_trajectory 0, n_actions 515, video_rendered 1 |
| L✓ 5m | 10-01 02:43 | 5m | 29 | 753k / 8k | $0.232 | $0.252 | deterministic 1, grader_error 0, live_success 1, missing_log 0, n_actions 348, replay_success 1, video_rendered 1 |
Task instruction (upstream)
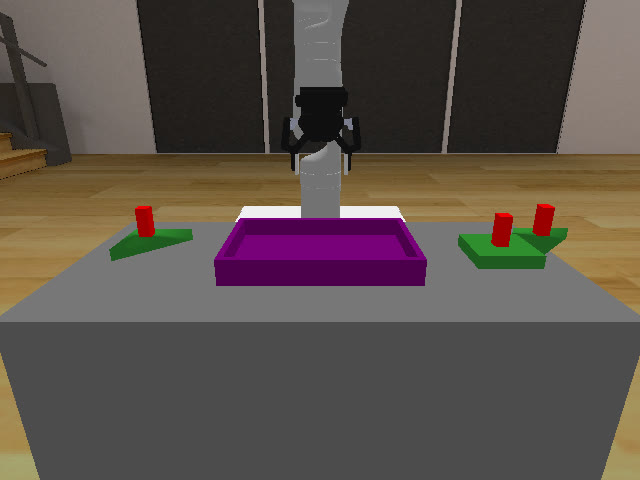
Put the three flat green parts on the grey table, a square (part0) and two right triangles (part1, part2), each with a small red peg on top, into the purple tray in the middle of the table (rack). The task succeeds the moment the robot holds nothing and every part rests in the tray: its flat body (peg excluded) lies within the tray's inner outline, its underside is within 5 mm of the tray floor's height and its top is no more than 5 mm above the tray's rim, it is within 5 mm of the tray without penetrating it, and no two parts (pegs included) overlap.
What KinDER states about this task
| Success criteria | 1. KinDER's own goal check (the environment's terminated) fires within the episode: at most 3000 control steps; no partial credit2. unlimited: both fresh-process replays of the handed-in trajectory reach it and end in the same state 3. limited: the one episode reaches it (no reset in our runs); the service records the episode, and it replays to the same state |
| Limited Instruction | Put the three flat green parts on the grey table, a square and two right triangles, each with a small red peg on top, into the purple tray in the middle of the table. The task succeeds the moment the robot holds nothing and every part rests in the tray: its flat body (peg excluded) lies within the tray's inner outline, its underside is within 5 mm of the tray floor's height and its top is no more than 5 mm above the tray's rim, it is within 5 mm of the tray without penetrating it, and no two parts (pegs included) overlap. |
| Env Id | kinder/Packing3D-p3-v0 |
| Robot | TidyBot++, kinematic: holonomic base, Kinova Gen3 7-DoF arm, gripper; a move that would collide is not carried out |
| Category | Kinematic3D (PyBullet) |
| Instance | seed 0: the scene KinDER builds from it, pinned by its digest |
| Holding Still | does not reach the goal (checked by running an episode of zero actions) |
| Action Dim | 11 |
| Actions | bounded relative base position, rotation, and joint positions, and open / close; each base and joint delta at most 0.2 a step |
| State Dim | 67 |
| Limited Mode | base RGB and wrist RGB-D cameras (480×640), base odometry, the arm's joint angles, the fingers' position; a move that would collide comes back blocked. Not where any object or the goal region is, not the goal check before the episode ends |
| Agent Budget | 3600 s of wall clock per mode |
From https://github.com/Princeton-Robot-Planning-and-Learning/kindergarden @ 5b2dbac, as defined in our task definitions @ 7d6a7a44.
Tags
Why this task is interesting
A square and two right triangles go into a tray, flat, inside its outline and without overlapping. The hard part is letting go: a held part is released only within 5 mm of a surface that supports it, a move that would collide is not carried out, and whether a part sits right can only be judged from the cameras.
Capability notes
Not yet written.
Oracle demo review
No demo.
Discussion
Both modes pass without a reset, limited mode in its first episode in under five minutes. (@williamzhangNU)