Sweeping Garage
Agent runs
Each mode of this task runs once per run. Est. cost is tokens at list price (data/prices.yml), never a bill; see the BEHAVIOR-1K runs for every task of a run.
Codex + GPT-6 Luna, reasoning xhigh (ChatGPT login)default run
Not in this run: not among the 30 chosen for the first round (2026-09-26): mostly particles, cutting and liquids, or long tidy-ups like chosen ones
No instruction published upstream
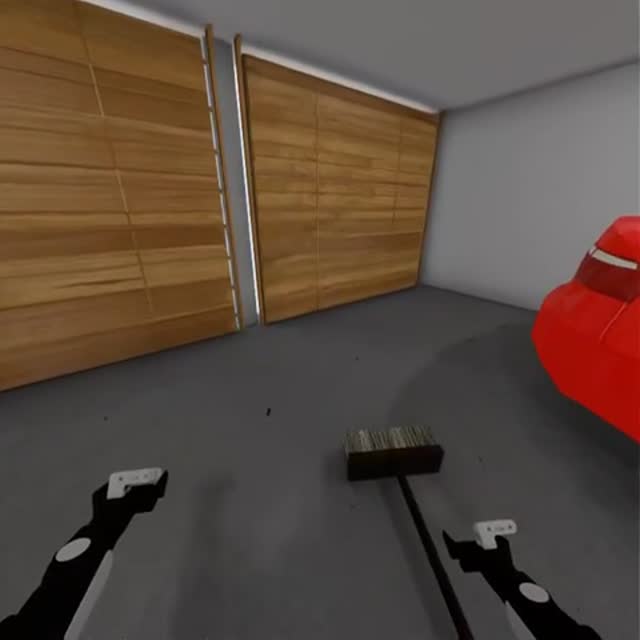
The 2025 carryover tasks ship without instruction text. Watch the demo and write the goal in your own words below, clearly marked as a reconstruction rather than the official goal.
Measured on the stack we run — BEHAVIOR-1K v3.9.2 / OmniGibson 3.9.2 / Isaac Sim 5.1
| Goal predicates | covered |
| Goal clauses | 2 |
| Objects named in the goal | dust.n.01 floor.n.01 sand.n.04 |
| Objects in the problem | 6 in 6 categories |
| Rooms loaded | garage_0 corridor_0 |
| Demonstrations | 200 teleoperated episodes |
| Mean episode | 2m 29s (4,473 control steps at 30 Hz) |
| Base travel, mean | 19.08 m |
| Gripper travel, mean | left 4.33 m · right 4.44 m |
| Evaluation instances | 20 public test instances (ids 301–320) |
Read from BDDL activity definitions + 2026-challenge-task-instances (licensed download), 2026-09-21.
Tags
Task DomainMobile / Whole-body Manipulation
Why this task is interesting
Not yet written.
Capability notes
Not yet written.
Oracle demo review
Not yet reviewed.