Putting Shoes On Rack
Agent runs
Each mode of this task runs once per run. Est. cost is tokens at list price (data/prices.yml), never a bill; see the BEHAVIOR-1K runs for every task of a run.
Codex + GPT-6 Luna, reasoning xhigh (ChatGPT login)default run
| Trial | Started | Agent time | Model requests | Tokens in / out | Est. cost | Grade |
|---|---|---|---|---|---|---|
| U✗ 4h 00m 70% | 09-27 10:10 | 4h 00m | 484 | 61.5M / 232k | $0.815 | deterministic 1, grader_error 0, instance_exact 0, instance_ok 1, n_actions 7272, video_rendered 1 |
| L✗ 4h 00m 20% | 09-27 11:10 | 4h 00m | 548 | 62.7M / 216k | $0.824 | deterministic 0, grader_error 0, live_success 0, n_actions 31356, replay_success 0, video_rendered 0 |
Task instruction (upstream)
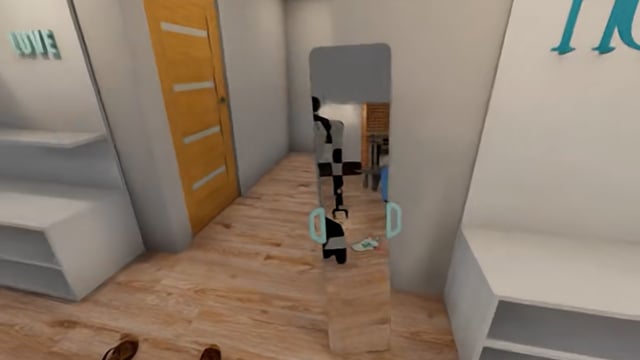
Pick up the two gym shoes and the two sandals from the corridor floor and place them onto the hallstand (shoe rack) in the corridor, making sure they are on the rack and not on the floor. Arrange them so the two gym shoes are next to each other and the two sandals are next to each other.
Measured on the stack we run — BEHAVIOR-1K v3.9.2 / OmniGibson 3.9.2 / Isaac Sim 5.1
| Goal predicates | nextto touching |
| Quantifiers | forall |
| Goal clauses | 4 |
| Objects named in the goal | floor.n.01 gym_shoe.n.01 hallstand.n.01 sandal.n.01 |
| Objects in the problem | 7 in 5 categories |
| Rooms loaded | corridor_0 garden_0 kitchen_0 living_room_0 |
| Demonstrations | 200 teleoperated episodes |
| Mean episode | 4m 18s (7,726 control steps at 30 Hz) |
| Base travel, mean | 27.02 m |
| Gripper travel, mean | left 8.85 m · right 9.75 m |
| Evaluation instances | 20 public test instances (ids 301–320) |
Read from BDDL activity definitions + 2026-challenge-task-instances (licensed download), 2026-09-21.
Tags
Task DomainMobile / Whole-body Manipulation
Why this task is interesting
Not yet written.
Capability notes
Not yet written.
Oracle demo review
Not yet reviewed.