Franka · Open
Agent runs
Each mode of this task runs once per run. Est. cost is tokens at list price (data/prices.yml), never a bill; see the MolmoSpaces runs for every task of a run.
Codex CLI 0.157–0.159 + GPT-6 Luna, reasoning medium (OpenRouter)default runclosed
| Trial | Started | Agent time | Model requests | Tokens in / out | Est. cost | Grade |
|---|---|---|---|---|---|---|
| U✓ 9m | 10-03 21:15 | 9m | — | 1.0M / 26k | $0.029 | deterministic 1, grader_error 0, n_actions 169, replay_success 1, video_rendered 1 |
| L✗ 15m | 10-03 18:49 | 15m | — | 4.9M / 60k | $0.089 | deterministic 1, grader_error 0, live_success 0, n_actions 455, replay_success 0, video_rendered 1 |
Task instruction (upstream)
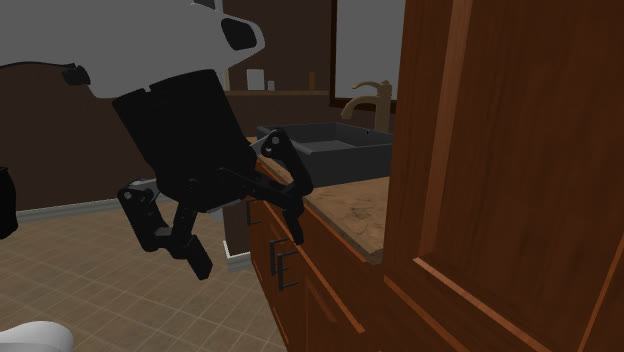
Open the drawer.
What MolmoSpaces states about this task
| Success criteria | 1. some joint of any drawer in the room is open at least 15% of its range (all start closed) 2. judged at the end of the episode: the trajectory's last row (privileged), done (standard) or 455 control steps (the benchmark's 30 s horizon), whichever comes first3. unlimited (privileged): both fresh-process replays of the handed-in trajectory end in the same state, and the check holds on it 4. limited (standard): the one episode (no reset) is recorded by the service and replays to the same state; the check holds on it live and in the replay |
| Family | open |
| Robot | Franka FR3 with a Robotiq 2F-85 gripper on a fixed base (the DROID setup) |
| Category | Franka |
| Instance | molmospaces-bench-v2/20260415, package ithor/FrankaOpenHardBench/FrankaOpenHardBench_20260206_json_benchmark, episode 1427 |
| Deliverable | /app/output/trajectory.npz with actions: float64 (T, 8), one row per control step, the targets of upstream's joint-position controllers |
| Reference Solution | None is shipped. Upstream's scripted experts (molmo_spaces/policy/solvers) are reference solutions and are not in the image; neither are grasp files nor the public MolmoBot trajectories (agent egress: the model APIs only). |
| Limited Mode | Standard-mode twin of molmospaces-open-i00-privileged (the same frozen MolmoSpaces episode): Open the drawer. The agent gets only the eai-standard/2.2 client (docs/STANDARD_MODE_2_2.md); the simulator runs in the sim sidecar (environment/docker-compose.yaml), which owns the episode, serves cameras, proprioception and upstream's kinematic model, and records every executed row. The collect hook (environment/sim/finalize.sh) ends the episode, lets the service exit, replays the trajectory in two fresh processes and writes final.json; the verifier grades those artifacts in a separate sandbox (tests/Dockerfile). |
| Oracle | none — no reference solution (MolmoSpaces' planners and grasp files are not shipped); positive example graded 1 by the separate verifier: molmospaces-open-i00-privileged__zxfmJNN (run codex-gpt6_luna-medium, batch molmospaces-luna-1003; https://embodied-agent-interface-v2-internal.github.io/runs/molmospaces/codex-gpt6_luna-medium-openrouter/open/unlimited/); human review in PR #47 |
| Base Image | ghcr.io/mll-lab-nu/eai-molmospaces:0.2.0 |
| Agent Budget | 3600 s of wall clock per mode |
| Task Dirs | molmospaces-open-i00-privileged, molmospaces-open-i00-standard |
From https://github.com/allenai/molmospaces @ molmo-spaces 0.2.9 (benchmark molmospaces-bench-v2/20260415), as defined in our task definitions @ 030f55607.
Tags
Why this task is interesting
Open a drawer in a hand-built kitchen, in upstream's Hard configuration: the arm starts in a random posture and the robot is turned away from the fixture. The drawer pull is low, and the slide direction has to be worked out before pulling.
Capability notes
Not yet written.
Oracle demo review
No demo.
Discussion
Both modes first pulled along the wrong axis; in limited mode the agent never recovered. Finding the joint's direction is this family's core difficulty. (@williamzhangNU)