Manipulation · Spoon
Excluded from the benchmark
its bar does not measure the task: holding still earns 58% of it (robot_coding_bench 2026-10-04)
Greyed and last in the task list, left out of the benchmark's numbers; its demo and agent runs stay (excluded: in state/tasks/humanoidbench.yml).
Agent runs
Each mode of this task runs once per run. Est. cost is tokens at list price (data/prices.yml), never a bill; see the HumanoidBench runs for every task of a run.
Codex CLI 0.157–0.159 + GPT-6 Luna, reasoning medium (OpenRouter)default run
| Trial | Started | Agent time | Model requests | Tokens in / out | Est. cost | Grade |
|---|---|---|---|---|---|---|
| U✗ 1h 00m | 09-28 18:46 | 1h 00m | — | 21.5M / 239k | $0.391 | deterministic 1, grader_error 0, n_actions 1000, video_rendered 1 |
| L✗ 1h 00m | 10-01 14:38 | 1h 00m | — | 32.7M / 162k | $0.455 | deterministic 1, grader_error 0, live_success 0, missing_log 0, n_actions 117, replay_success 0, video_rendered 1 |
3 other run(s) of HumanoidBench
Codex CLI 0.159.2 + GPT-6.1 Sol, reasoning medium (OpenRouter)
| Trial | Started | Agent time | Model requests | Tokens in / out | Est. cost | Billed | Grade |
|---|---|---|---|---|---|---|---|
| U✗ 1h 00m | 10-01 04:49 | 1h 00m | 117 | 13.7M / 110k | $2.87 | $2.98 | deterministic 1, grader_error 0, n_actions 1000, video_rendered 1 |
| L✗ 1h 00m | 10-01 00:25 | 1h 00m | 161 | 17.2M / 81k | $2.94 | $3.05 | deterministic 1, grader_error 0, live_success 0, missing_log 0, n_actions 140, replay_success 0, video_rendered 1 |
Claude Code 2.1.283 + Claude Opus 5.5, reasoning medium (OpenRouter)
Not in this run: not in this run (the two dearer models ran five tasks, chosen to span locomotion and manipulation, easy to hard)
Codex CLI 0.157.0 + GPT-6 Sol, reasoning medium (OpenRouter)closed
Not in this run: not in this run (the two dearer models ran five tasks, chosen to span locomotion and manipulation, easy to hard)
Task instruction (upstream)
Take hold of the spoon, put it in the cup and stir: move its head around a small circle, continuously, for the rest of the episode.
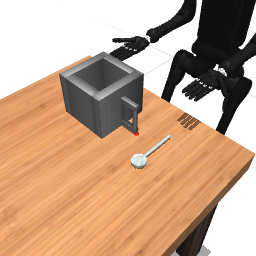
What HumanoidBench states about this task
| Success criteria | 1. the summed per-step reward over one episode reaches 650, HumanoidBench's own success bar (a total of rewards, not a number of steps; an episode is at most 1000 control steps) 2. unlimited: both fresh-process replays of the handed-in trajectory reach it and end in the same state 3. limited: the run passes the moment a live episode reaches it (the recorded episode replays to the same state); otherwise the last episode is graded |
| Env Id | h1hand-spoon-v0 |
| Robot | Unitree H1 with two Shadow hands (61 actuators) |
| Category | Manipulation |
| Capability Class | C6 · standing bimanual manipulation |
| Role | scored |
| Scoring | A weighted sum of four things: standing steadily, getting a hand to the spoon's handle, keeping the spoon's head inside the cup, and — the largest single term — keeping that head close to a target point that travels around a small circle at a fixed rate, completing a revolution every 40 steps (centred in the cup just above its floor, counter-clockwise seen from above, starting on the side away from the robot). The spoon starts on the table beside the cup, so the last two terms pay nothing until it is in the cup. |
| Ends Early | The episode ends if the pelvis drops too low. |
| Zero Action Return | 7.48 |
| Action Dim | 61 |
| Control Rate Hz | 50 |
| Limited Mode | head cameras (RGB 256×256), joint angles and velocities; a pelvis IMU and a camera fixed in the room when the run turns them on. Not where the robot is in the room, not the spoon's pose, not the moving target point, not the reward |
| Agent Budget | 3600 s of wall clock per mode |
From https://github.com/carlosferrazza/humanoid-bench @ cb11890, as defined in our task definitions @ 7d6a7a44.
Tags
Why this task is interesting
A five-fingered hand has to pick a thin spoon up from the table, bring it over the cup's rim into the cup, then stir in circles of 40 steps.
Capability notes
Not yet written.
Oracle demo review
No demo.
Discussion
Blocked on stirring: unlimited mode lifts the spoon into the cup but never stirs, and limited mode never holds the handle. (@williamzhangNU)