Manipulation · Package
Agent runs
Each mode of this task runs once per run. Est. cost is tokens at list price (data/prices.yml), never a bill; see the HumanoidBench runs for every task of a run.
Codex CLI 0.157–0.159 + GPT-6 Luna, reasoning medium (OpenRouter)default run
| Trial | Started | Agent time | Model requests | Tokens in / out | Est. cost | Grade |
|---|---|---|---|---|---|---|
| U✗ 1h 00m | 10-04 05:44 | 1h 00m | — | 25.8M / 242k | $0.469 | deterministic 1, grader_error 0, n_actions 93, video_rendered 1 |
| L✗ 8m | 10-04 06:14 | 8m | — | 3.7M / 42k | $0.066 | deterministic 1, grader_error 0, live_success 0, missing_log 0, n_actions 1000, replay_success 0, video_rendered 1 |
3 other run(s) of HumanoidBench
Codex CLI 0.159.2 + GPT-6.1 Sol, reasoning medium (OpenRouter)
| Trial | Started | Agent time | Model requests | Tokens in / out | Est. cost | Billed | Grade |
|---|---|---|---|---|---|---|---|
| U✗ 1h 00m | 10-01 03:42 | 1h 00m | 130 | 12.4M / 123k | $2.87 | $2.98 | deterministic 1, grader_error 0, n_actions 995, video_rendered 1 |
| L✗ 1h 00m | 09-30 23:40 | 1h 00m | 124 | 15.0M / 104k | $2.98 | $3.10 | deterministic 1, grader_error 0, live_success 0, missing_log 0, n_actions 230, replay_success 0, video_rendered 1 |
Claude Code 2.1.283 + Claude Opus 5.5, reasoning medium (OpenRouter)
Not in this run: not in this run (the two dearer models ran five tasks, chosen to span locomotion and manipulation, easy to hard)
Codex CLI 0.157.0 + GPT-6 Sol, reasoning medium (OpenRouter)closed
Not in this run: not in this run (the two dearer models ran five tasks, chosen to span locomotion and manipulation, easy to hard)
Task instruction (upstream)
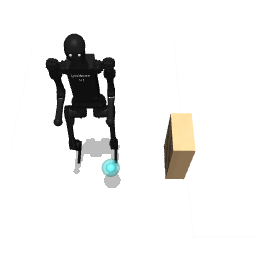
Walk to the package, pick it up, carry it to the destination marker and set it down there, standing upright.
What HumanoidBench states about this task
| Success criteria | 1. the summed per-step reward over one episode reaches 1500, HumanoidBench's own success bar (a total of rewards, not a number of steps; an episode is at most 1000 control steps) 2. unlimited: both fresh-process replays of the handed-in trajectory reach it and end in the same state 3. limited: the run passes the moment its one episode reaches it (no reset in our runs since 2026-10-04; the recorded episode replays to the same state) |
| Env Id | h1-package-v0 |
| Robot | Unitree H1 (19 actuators) |
| Category | Manipulation |
| Capability Class | C8 · mobile manipulation |
| Role | scored |
| Scoring | Every step charges you for the distance from the package to its destination — the largest term by far — and a little for the distance from each hand to the package; against that you earn a share for standing steadily and a share for how high the package is off the ground. So the return is strongly negative while the package sits on the floor away from its destination, and improves as you close the distance with it lifted. Landing the package on the destination pays a one-off bonus and ends the episode, but the bonus alone is short of the bar: the rest has to come from the per-step terms before the landing, and those only turn positive once the package is close to the destination. |
| Zero Action Return | -2191.95 |
| Action Dim | 19 |
| Control Rate Hz | 50 |
| Limited Mode | head cameras (RGB 256×256), joint angles and velocities; a pelvis IMU and a camera fixed in the room when the run turns them on. Not where the robot is in the room, not where the package or the destination is, not the reward |
| Agent Budget | 3600 s of wall clock per mode |
From https://github.com/carlosferrazza/humanoid-bench @ cb11890, as defined in our task definitions @ 841996303.
Tags
Why this task is interesting
The package, a tall box of 0.4 × 0.2 × 0.7 m, stands about 0.86 m to the robot's left and about 0.7 m from the goal: the robot has to side-step to it and move it to the goal, while holding the starting pose falls after about 100 steps.
Capability notes
Not yet written.
Oracle demo review
No demo.
Discussion
Blocked on lifting: the unlimited runs move the box toward the goal without lifting it (GPT-6 Luna's lunge, 2026-10-04, pushes it to 8 cm from the marker: 870 of 1500), and limited mode's lifts slip. (@williamzhangNU)