Manipulation · Highbar simple
Agent runs
Each mode of this task runs once per run. Est. cost is tokens at list price (data/prices.yml), never a bill; see the HumanoidBench runs for every task of a run.
Codex CLI 0.157–0.159 + GPT-6 Luna, reasoning medium (OpenRouter)default run
| Trial | Started | Agent time | Model requests | Tokens in / out | Est. cost | Grade |
|---|---|---|---|---|---|---|
| U✗ 59m | 10-04 05:28 | 59m | — | 24.5M / 162k | $0.377 | deterministic 1, grader_error 0, n_actions 1000, video_rendered 1 |
| L✗ 7m | 10-04 05:29 | 7m | — | 3.0M / 40k | $0.059 | deterministic 1, grader_error 0, live_success 0, missing_log 0, n_actions 1000, replay_success 0, video_rendered 1 |
3 other run(s) of HumanoidBench
Codex CLI 0.159.2 + GPT-6.1 Sol, reasoning medium (OpenRouter)
| Trial | Started | Agent time | Model requests | Tokens in / out | Est. cost | Billed | Grade |
|---|---|---|---|---|---|---|---|
| U✗ 1h 00m | 10-01 03:45 | 1h 00m | 110 | 9.7M / 109k | $2.41 | $2.50 | deterministic 1, grader_error 0, n_actions 1000, video_rendered 1 |
| L✗ 1h 00m | 09-30 23:00 | 1h 00m | 137 | 14.4M / 112k | $3.66 | $3.95 | deterministic 1, grader_error 0, live_success 0, missing_log 0, n_actions 1000, replay_success 0, video_rendered 1 |
Claude Code 2.1.283 + Claude Opus 5.5, reasoning medium (OpenRouter)
Not in this run: not in this run (the two dearer models ran five tasks, chosen to span locomotion and manipulation, easy to hard)
Codex CLI 0.157.0 + GPT-6 Sol, reasoning medium (OpenRouter)closed
Not in this run: not in this run (the two dearer models ran five tasks, chosen to span locomotion and manipulation, easy to hard)
Task instruction (upstream)
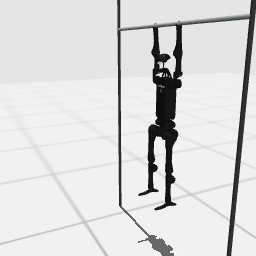
The robot starts hanging from a high bar. Swing up: get inverted and drive the feet as high as you can.
What HumanoidBench states about this task
| Success criteria | 1. the summed per-step reward over one episode reaches 750, HumanoidBench's own success bar (a total of rewards, not a number of steps; an episode is at most 1000 control steps) 2. unlimited: both fresh-process replays of the handed-in trajectory reach it and end in the same state 3. limited: the run passes the moment its one episode reaches it (no reset in our runs since 2026-10-04; the recorded episode replays to the same state) |
| Env Id | h1-highbar_simple-v0 |
| Robot | Unitree H1 (19 actuators) |
| Category | Manipulation |
| Capability Class | C5 · whole-body power and momentum |
| Role | scored |
| Scoring | Three multiplied requirements: how far the torso is towards inverted, how high the feet are, and low actuator force. Read the first one carefully — it rewards being upside down, so hanging the right way up scores nothing at all no matter how steady it is. The feet-height term saturates only when the feet are well above the bar. On this robot the forearms are fixed to the bar, so it cannot fall off. |
| Ends Early | The episode still ends if the head drops too low, which an inverted hang under the bar can do. |
| Zero Action Return | 0.08 |
| Action Dim | 19 |
| Control Rate Hz | 50 |
| Limited Mode | head cameras (RGB 256×256), joint angles and velocities; a pelvis IMU and a camera fixed in the room when the run turns them on. Not the robot's position or heading in the room, not the reward |
| Agent Budget | 3600 s of wall clock per mode |
From https://github.com/carlosferrazza/humanoid-bench @ cb11890, as defined in our task definitions @ 841996303.
Tags
Why this task is interesting
Hanging from a high bar, the robot swings up into a handstand with its feet well above the bar. Swinging through the handstand is not enough: it has to stop there.
Capability notes
Not yet written.
Oracle demo review
No demo.
Discussion
Out of reach for now: the robot swings up to a partial inversion but never holds the handstand; GPT-6 Luna's feedback-held swing (2026-10-04) came closest, 526 of 750. (@williamzhangNU)