Locomotion · Maze
Excluded from the benchmark
not among the hardest (robot_coding_bench 2026-10-04): passed in unlimited mode
Greyed and last in the task list, left out of the benchmark's numbers; its demo and agent runs stay (excluded: in state/tasks/humanoidbench.yml).
Agent runs
Each mode of this task runs once per run. Est. cost is tokens at list price (data/prices.yml), never a bill; see the HumanoidBench runs for every task of a run.
Codex CLI 0.157–0.159 + GPT-6 Luna, reasoning medium (OpenRouter)default run
| Trial | Started | Agent time | Model requests | Tokens in / out | Est. cost | Grade |
|---|---|---|---|---|---|---|
| U✗ 1h 00m | 09-28 17:44 | 1h 00m | — | 27.1M / 203k | $0.430 | deterministic 1, grader_error 0, n_actions 1000, video_rendered 1 |
| L✗ 45m | 10-01 14:17 | 45m | — | 20.8M / 134k | $0.308 | deterministic 1, grader_error 0, live_success 0, missing_log 0, n_actions 1000, replay_success 0, video_rendered 1 |
3 other run(s) of HumanoidBench
Codex CLI 0.159.2 + GPT-6.1 Sol, reasoning medium (OpenRouter)
| Trial | Started | Agent time | Model requests | Tokens in / out | Est. cost | Billed | Grade |
|---|---|---|---|---|---|---|---|
| U✓ 1h 00m | 10-01 03:45 | 1h 00m | 117 | 12.3M / 84k | $2.39 | $2.48 | deterministic 1, grader_error 0, n_actions 1000, video_rendered 1 |
| L✗ 54m | 09-30 22:25 | 54m | 108 | 9.6M / 108k | $2.39 | $2.48 | deterministic 1, grader_error 0, live_success 0, missing_log 0, n_actions 181, replay_success 0, video_rendered 1 |
Claude Code 2.1.283 + Claude Opus 5.5, reasoning medium (OpenRouter)
Not in this run: not in this run (the two dearer models ran five tasks, chosen to span locomotion and manipulation, easy to hard)
Codex CLI 0.157.0 + GPT-6 Sol, reasoning medium (OpenRouter)closed
Not in this run: not in this run (the two dearer models ran five tasks, chosen to span locomotion and manipulation, easy to hard)
Task instruction (upstream)
Walk the robot along the maze's corridors from checkpoint to checkpoint, in order, turning at each corner, without hitting the walls.
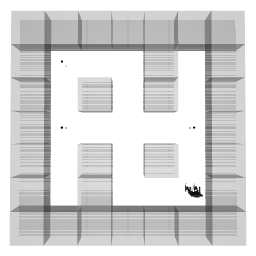
What HumanoidBench states about this task
| Success criteria | 1. the summed per-step reward over one episode reaches 1200, HumanoidBench's own success bar (a total of rewards, not a number of steps; an episode is at most 1000 control steps) 2. unlimited: both fresh-process replays of the handed-in trajectory reach it and end in the same state 3. limited: the run passes the moment a live episode reaches it (the recorded episode replays to the same state); otherwise the last episode is graded |
| Env Id | h1-maze-v0 |
| Robot | Unitree H1 (19 actuators) |
| Category | Locomotion |
| Capability Class | C4 · navigation and passage |
| Role | scored |
| Scoring | Most of the bar is not accumulated, it is jumped to: reaching a checkpoint pays a one-off bonus, and the bonuses grow with how many you have already reached, so the later corners are worth far more than the first. Between checkpoints each step pays a small amount for posture, for moving in the current corridor's direction (the speed target is on the order of 2 m/s) and for nearing the next checkpoint; touching a wall multiplies that per-step amount down to a fraction (the bonuses are not reduced). Walking correctly but never reaching a checkpoint leaves the episode below the bar. |
| Ends Early | The episode ends early if the pelvis drops near the ground. |
| Zero Action Return | 120.59 |
| Action Dim | 19 |
| Control Rate Hz | 50 |
| Limited Mode | head cameras (RGB 256×256), joint angles and velocities; a pelvis IMU and a camera fixed in the room when the run turns them on. Not where the robot is in the maze, not where the checkpoints are, not the reward |
| Agent Budget | 3600 s of wall clock per mode |
From https://github.com/carlosferrazza/humanoid-bench @ cb11890, as defined in our task definitions @ 7d6a7a44.
Tags
Why this task is interesting
The robot walks the corridors of a maze through checkpoints at three corners. Most of the reward is the checkpoint bonuses, which grow along the way, so upright walking with turns comes before anything else.
Capability notes
Not yet written.
Oracle demo review
No demo.
Discussion
Passes in unlimited mode with whole-body control walking a planned route through every checkpoint without touching a wall; limited mode never gets past the first stage. (@williamzhangNU)